Jump to main content
Computer Engineering
Computer Engineering 

← Back to Demonstrators

Indoor Real-Time Location System (RTLS)

Active
Drone
TUC Contact Prof. Dr. Dr. h. c. Wolfram Hardt wolfram.hardt@cs.tu-chemnitz.de

The Indoor Real-Time Locating System was developed as part of the development projects within the Indoor Flight Center (IFC) and serves as an emulation of real-world GNSS signals within an enclosed indoor environment.

Purpose & Motivation

To ensure successful navigation and accurate position detection, the copter requires a precise and constantly reliable position. Since the copter is continuously in motion, the position data must be updated in real-time. However, testing these hardware and software solutions inside the Indoor Flight Center (IFC) presents a significant challenge due to the lack of proper GNSS satellite signals. Therefore, to make indoor testing possible, an independent real-time positioning system had to be implemented to overcome the GNSS reception problem within the indoor facility.
Technical Description

The Indoor Real-Time Locating System (RTLS) powered by Ultra-Wideband (UWB) technology offers unprecedented precision for tracking the position of a flying UAV within enclosed spaces. Unlike traditional technologies like Bluetooth or Wi-Fi that rely on signal strength, UWB operates by transmitting short radio pulses across a very wide frequency spectrum, allowing the indoor location system to calculate the UAV’s precise position down to a few centimeters. By measuring the Time of Flight (ToF) or Time Difference of Arrival (TDOA) between tags and fixed anchors, UWB provides exceptional immunity to multipath interference and high accuracy inside our Indoor Flight Center

Capabilities

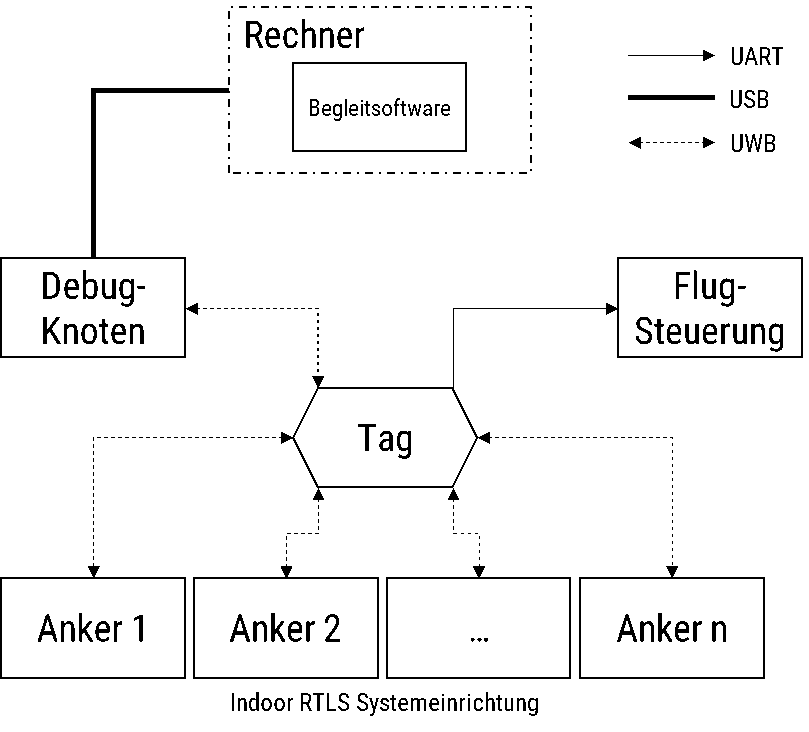
The position determination of the indoor RTLS relies on several key techniques to accurately locate a tag in the 3D space. Time of Flight (ToF) calculates the distance by measuring the transmission duration between a tag and several anchors using the formula “Distance = Duration × Speed of Light”, pinpointing the tag’s location via the intersection of multiple spheres. Alternatively, Time Difference of Arrival (TDOA) measures the time differences of the tag’s messages to find the positions at the intersection of hyperboloids, requiring strict synchronization. In order to achieve a unique and precise 3D position, the three-dimensional multilateration requires at least four anchors with pre-known coordinates and specific placement relative to the tag. The GNSS coordinates’ position transmission computes the global position using the tag’s local coordinates’ and anchor’s GNSS data, subsequently converting these positions into NMEA sentences that are transmitted via UART to the flight controller, while the debug data is simultaneously sent to a Debug Node for monitoring purposes.

Research Context

Related Demonstrator: Indoor Flight Center (IFC)

Visuals

Short description of what the image shows

Social Media

Connect with Us: