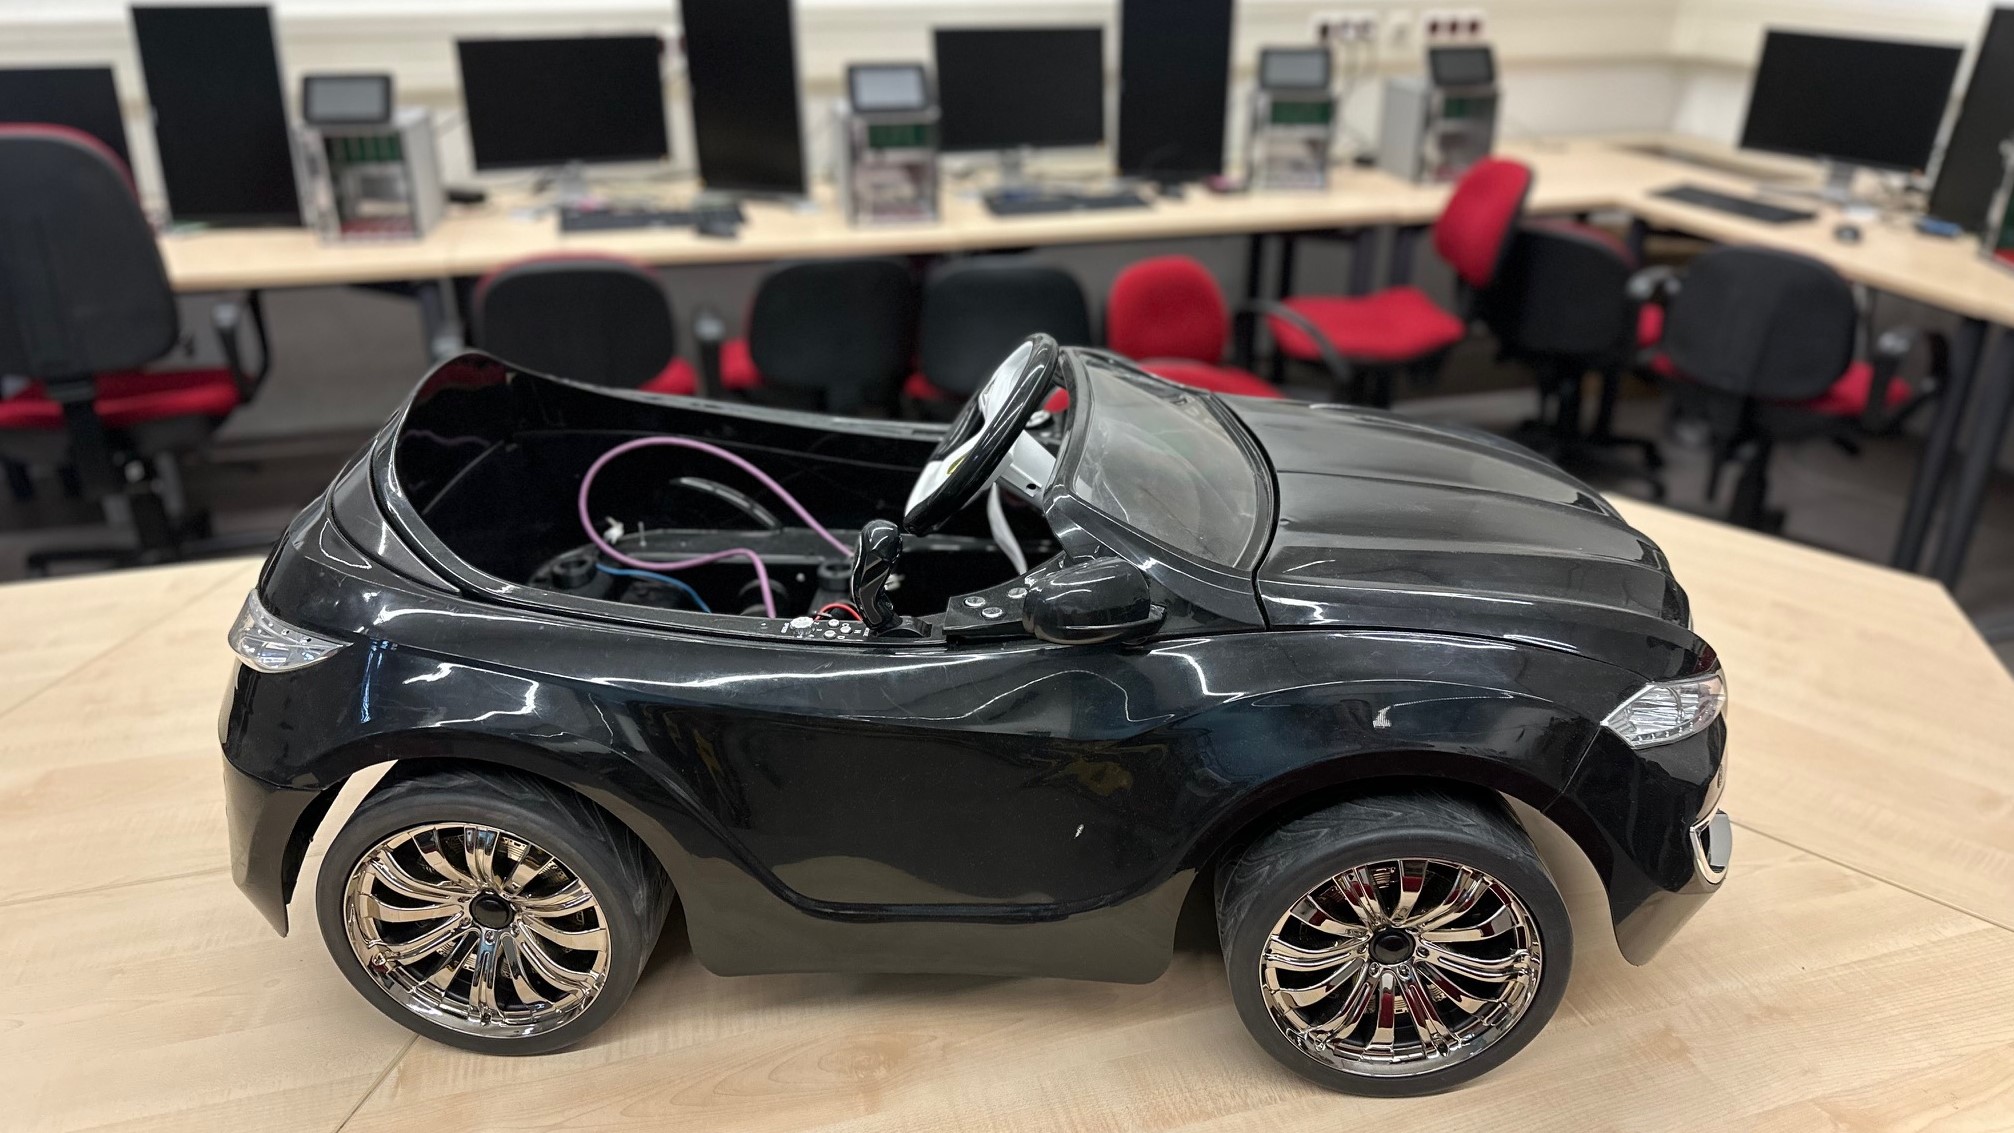
Industrial vehicle software platforms are too costly for everyday research and teaching, so we built YellowCar and BlackPearl — alongside TUCMini, TUCBox, and CARLA — to develop and validate distributed architectures and Car2X communication, proving automated driving functions are safe before they reach the road.
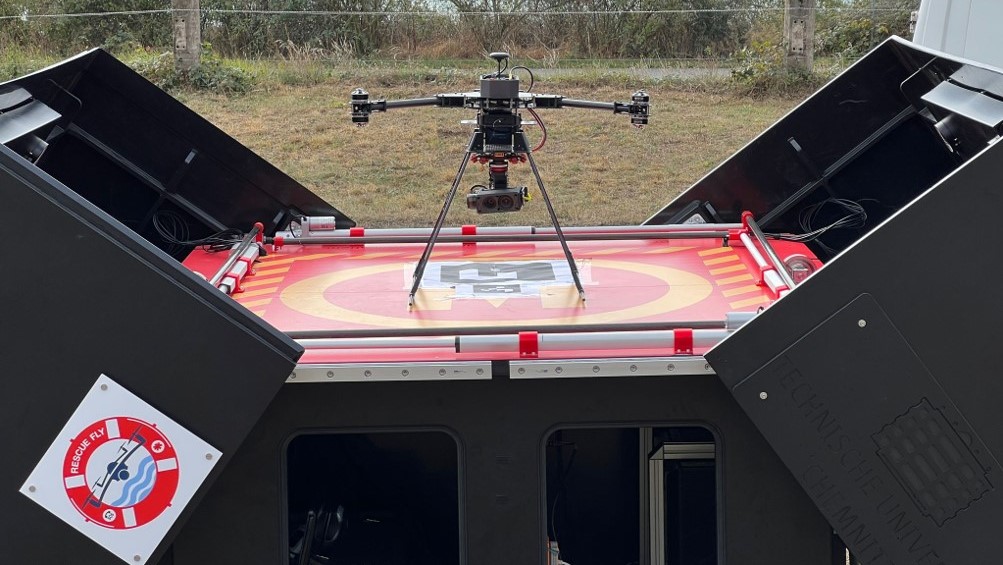
Autonomous flight demands reliable control, sensing, and coordination under real-world conditions, which we research with InterCEpter and AREIOM for flight control and sensor fusion, tested in the Indoor Flight Center and Hangar, and extended through Drone Fleet and RTLS to coordinate and track multiple drones at once.
AI systems are only as good as the data and algorithms behind them, so we test driving algorithms with the CARLA simulator, apply the Intelligent Frame Extractor for object detection, and run the AI Data Monitoring Platform to validate data in real time, letting AI be deployed with confidence.
By clicking the links below, you allow personal data to be transmitted to Third Party Websites. This may require the storage of cookies on your device.
You can find more information about the University data protocols about data security here.
Drohnen: Kleine Helfer, große Möglichkeiten
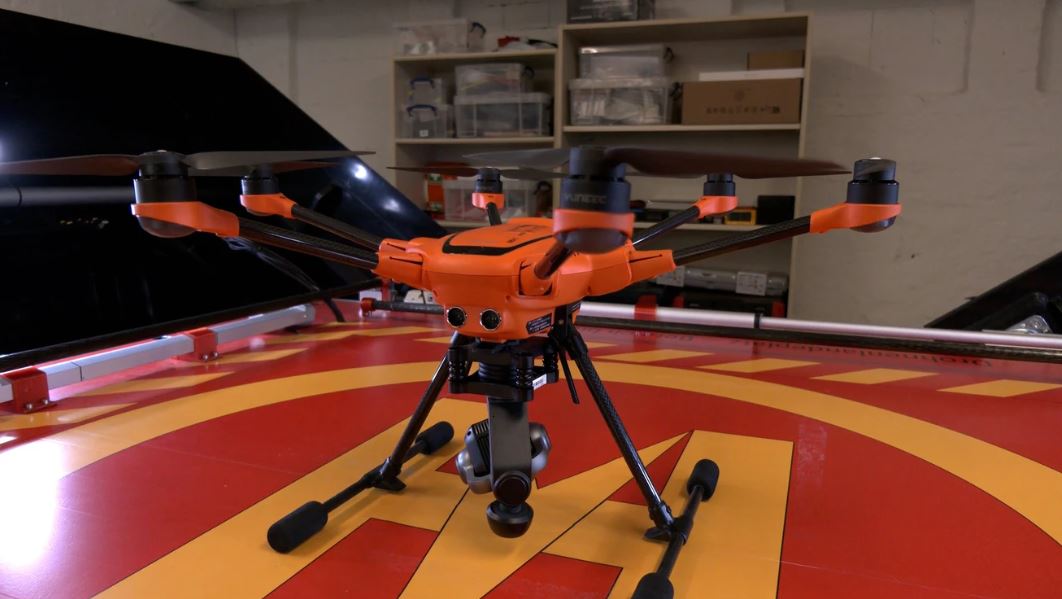
Drohnen mit KI sollen Leben retten
Drohnen mit KI sollen Leben retten