Yellow Car
The YellowCar is a research and teaching demonstrator for automotive softwareengineering. It enables students and researchers to develop, test, and validate distributed automotive software architectures and embedded control functions on a realistic vehicle platform based on AUTOSAR and CAN communication.
Purpose & Motivation
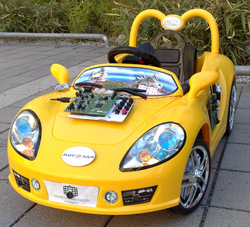
Modern vehicles contain numerous interconnected electronic control units (ECUs), making software architecture and system integration increasingly complex. Industrial development platforms are often expensive and difficult to access for education. The YellowCar addresses this challenge by providing an affordable, modular demonstrator that bridges the gap between theoretical education and practical automotive software development. It enables hands-on experience with distributed embedded systems, automotive communication, diagnostics, and software testing.
Technical Description
The demonstrator is based on a modified electric ride-on vehicle equipped with three Freescale S12XEP100 Electronic Control Units (ECUs) connected via a 125 kbit/s CAN bus. The software architecture follows the AUTOSAR 2.1 standard.
Hardware
- Electric ride-on vehicle
- Three ECUs (Freescale S12XEP100)
- CAN bus (125 kbit/s)
- High-capacity battery
- Improved traction
- Headlights, rear lights and turn indicators
- Ultrasonic distance sensors (front and rear)
- Light and temperature sensors
- Wheel-speed sensor
- On-board server for diagnostics and remote access
Software & Development Environment
- AUTOSAR 2.1
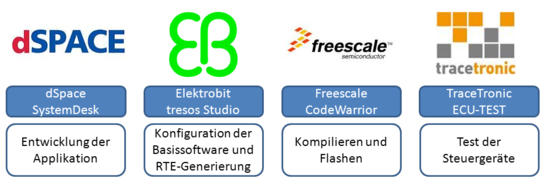
- dSPACE SystemDesk
- Elektrobit tresos Studio
- AUTOSAR Runtime Environment (RTE)
- Freescale CodeWarrior
- TraceTronic ECU-TEST (Hardware-in-the-Loop)
System Architecture
The system consists of three distributed ECUs:
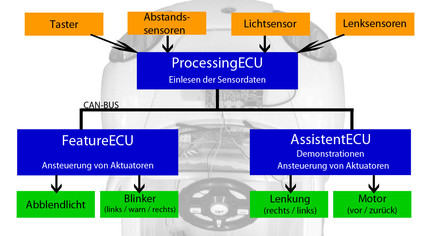
- ProcessingECU: Sensor acquisition and data distribution
- FeatureECU: Vehicle lighting control
- AssistantECU: Driving functions including steering and propulsion
Capabilities
The YellowCar supports a variety of demonstrations and experiments, including:
- Automated driving functions
- Remote vehicle control
- On-board diagnostics
- Distributed ECU communication
- Sensor integration
- Vehicle lighting control
- Obstacle detection and avoidance
- Hardware-in-the-loop testing
Demonstration scenarios include:
- Automated forward driving until obstacle detection
- Circular driving manoeuvres
- Obstacle avoidance
- Remote operation via Android, iOS or web application
- Live monitoring of vehicle sensor and CAN bus data
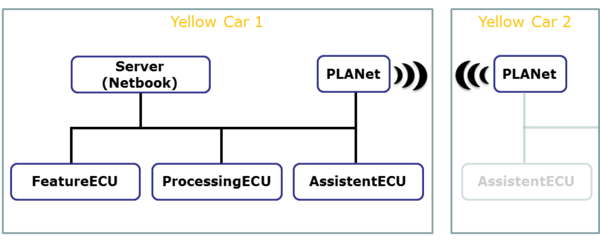
Additionally, two YellowCars can communicate via a Car-to-Car communication platform to demonstrate cooperative driving scenarios such as emergency braking and collision avoidance.
Research Context
The YellowCar is used for research and education in:
- Automotive Software Engineering
- AUTOSAR-based software development
- Embedded Systems
- Distributed Control Systems
- CAN communication
- Hardware-in-the-Loop testing
- Vehicle diagnostics
- Vehicle-to-Vehicle (V2V) communication
- Model-based software development