CARLA
Active
CARLA Simulator is an open-source autonomous driving simulator that provides a realistic environment for developing and evaluating autonomous driving algorithms. It enables safe, cost-effective testing by generating diverse traffic scenarios and synchronized sensor data without requiring real-world experiments.
Purpose & Motivation
The purpose of using CARLA in our labs is to test our developed autonomous driving algorithms and processes on realistic driving simulation environments, integrating state-of-the-art Artificial Intelligence technologies.
Technical Description
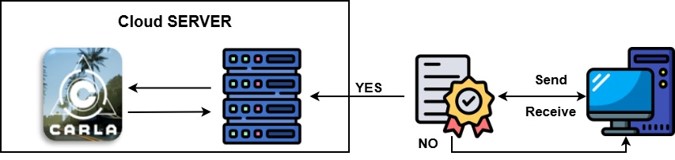
Hardware
- ASUS GPU RTX Server Barebone ESC4000-E10 2U
- Intel Xeon Silver 4309Y processor 2.8 GHz (8 cores)
- Memory 128 GB (8x 16 GB) DDR4 ECC registered 3200 MHz
- PNY NVIDIA Ampere A10-24GB PCIe 4.0 Data Center GPU
- Broadcom NetXtreme-E Series P210P server network card, 2x 10 Gbit/s
- 2.0TB Samsung PM9A1 M.2 NVMe SSD
- 1.92TB Kioxia CD8-R SSD
Software
Linux OS
Capabilities
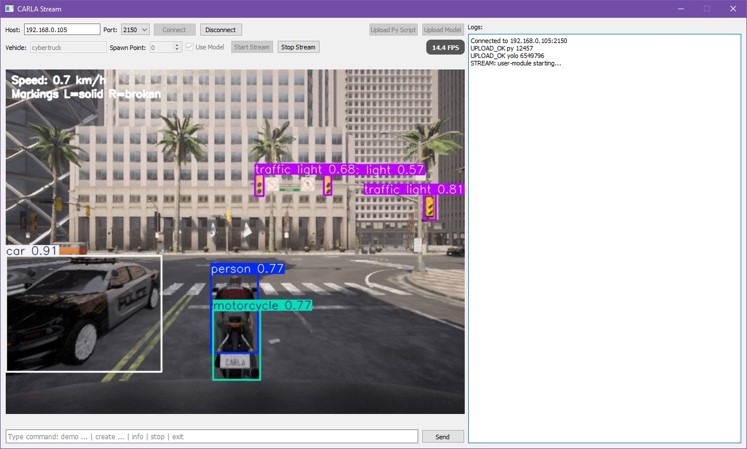
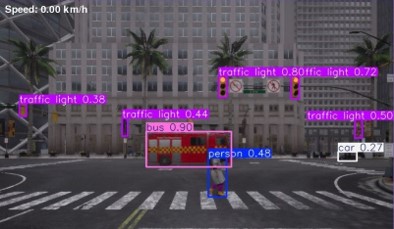
- Traffic Signs Detection & Recognition
- Autonomous Driving
- Lane Crossing Situations
- Bus Stop Situations
- Autonomous Driving Beginner Level Game
- Customised Map Design (Work In Progress)
Research Context
- Artificial Intelligence-Based Algorithms Development
- Expert Systems-Based Driving Rules Actuation